
How to Improve Robotic Bin Picking 3D Vision Accuracy
Publication Date
author
Improving robotic bin picking 3d vision accuracy is no longer just a software issue—it directly affects throughput, grasp success, and procurement decisions across advanced manufacturing. For engineers, operators, buyers, and decision-makers evaluating automation stacks alongside servo motor for cnc router performance, agv charging station setup, and amr fleet management software, this guide breaks down the practical factors that determine real-world 3D vision reliability.
In practical production cells, a 3D vision system that performs well in a showroom can still fail on reflective castings, dark rubber parts, mixed bins, or fast cycle requirements. A difference of 1.5 mm in pose estimation, or a 300 ms delay in point cloud processing, can reduce successful picks per hour, increase robot idle time, and distort the ROI model used by procurement teams.
For TSV’s audience, the right question is not whether a system supports robotic bin picking, but under what conditions it sustains accuracy: part geometry, surface finish, bin depth, ambient light, camera baseline, calibration drift, and gripper tolerance. This article focuses on those measurable variables so selection and deployment decisions can be based on engineering truth rather than generic marketing claims.
Why 3D Vision Accuracy Fails in Real Bin Picking Environments
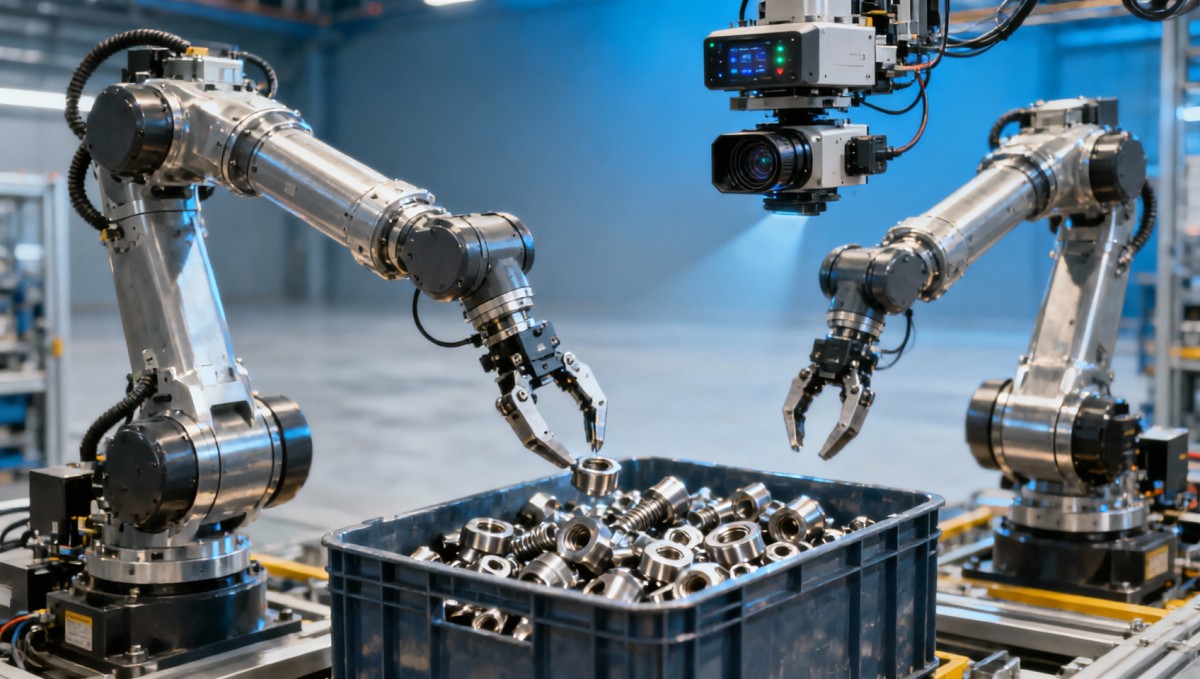
Robotic bin picking 3D vision accuracy is challenged by a combination of scene complexity and process instability. In most cells, the issue is not a single bad sensor. It is the accumulation of errors across optics, lighting, robot calibration, part presentation, and software inference. When those small deviations stack up, the result is poor pose estimation and inconsistent grasp planning.
Occlusion is one of the most common causes. When 30% to 70% of a target part is hidden by overlapping components, the vision system must infer geometry from incomplete data. This becomes more difficult with thin sheet metal, reflective machined parts, transparent plastics, or mixed SKUs in one tote. If the point cloud density drops below a usable threshold, the pick engine may identify the part class correctly but still miss the grasp pose.
Another frequent issue is environmental variability. A plant may operate at 10°C in winter startup and 35°C near heat-generating equipment, while vibration from nearby conveyors or stamping cells introduces motion noise. In such conditions, even a camera specified at sub-millimeter lab accuracy may shift outside a stable production tolerance if it is not mounted, shielded, and recalibrated correctly.
Cycle time pressure also degrades performance. If a line requires 6 to 10 picks per minute and the vision stack needs 1.2 seconds for capture, 0.8 seconds for reconstruction, and 0.6 seconds for matching, the robot may either wait or attempt picks based on stale scene data. Accuracy is therefore inseparable from latency. A slower but nominally precise system can still lower total throughput.
Typical root causes engineers should isolate
- Misalignment between camera coordinate system and robot base frame, often exceeding ±1.0 mm after tool changes or fixture movement.
- Insufficient point cloud quality caused by shiny, black, transparent, or oil-coated surfaces.
- Inconsistent lighting from skylights, welding arcs, or open cell design that affects projected pattern or stereo contrast.
- CAD mismatch, where the actual part has burrs, deformation, or lot-to-lot variation outside the digital model assumptions.
- Gripper design that leaves too little pose tolerance, for example requiring orientation error below 2° when the vision process can only sustain 3° to 5° in production.
Failure patterns by application type
The table below helps separate sensor-related problems from process-related problems. For procurement teams, this matters because replacing the camera alone often does not solve the failure mode. The more reliable investment is usually a matched package of optics, software, robot calibration routine, and end-of-arm tooling.
The key takeaway is that robotic bin picking 3D vision accuracy must be evaluated as a system-level metric. In most industrial deployments, acceptable results usually mean keeping positional error within roughly ±0.5 mm to ±2.0 mm, angular error within 1° to 5°, and end-to-end vision latency under 500 to 900 ms, depending on part size and gripper compliance.
The Core Technical Levers That Improve Accuracy
Improving accuracy starts with sensor-to-scene fit. Different 3D methods behave differently under real factory conditions. Structured light can offer fine detail for matte parts and controlled cells, while stereo or time-of-flight may better tolerate certain distance ranges or motion constraints. There is no universal best choice. The right decision depends on part material, bin geometry, required working distance, and target cycle time.
Mounting geometry is equally important. A camera placed too high reduces usable point density; too low, and the field of view cannot capture the full bin. In many systems, a working distance of 700 mm to 1500 mm is common, but the effective range must be tested against the smallest feature the matching engine needs. If the system must distinguish a 4 mm flange from a flat surface, resolution planning cannot be left to generic datasheets.
Calibration discipline often makes a larger difference than software version changes. Hand-eye calibration, tool center point verification, and bin reference frame updates should be controlled as part of routine maintenance. In cells with frequent tool changes or mobile platforms, a weekly check may be insufficient. Some operations need verification every shift or after every collision event above a defined threshold.
AI-based matching and grasp planning improve robustness, but only when trained on representative variation. If the training set excludes oily surfaces, partial deformation, or actual lot-level appearance changes, the model confidence score can look stable while physical pick outcomes deteriorate. For that reason, production image sets from 3 to 5 part lots are usually more valuable than a larger but cleaner lab dataset.
Sensor and setup choices that usually matter most
- Choose a sensor based on surface behavior, not brochure resolution alone. Reflective aluminum and black rubber require different approaches.
- Control lighting around the cell with shields, enclosures, or synchronized strobes, especially when ambient light changes across shifts.
- Match gripper tolerance to realistic vision output. A suction cup may tolerate more pose error than a tight jaw gripper.
- Use stable mounts with low vibration and thermal drift. A rigid bracket can save more downtime than a premium software add-on.
- Validate point cloud quality at the bin corners, not just at the center, because edge distortion frequently drives hidden misses.
Recommended engineering targets before full rollout
For many industrial programs, a practical pre-deployment target is at least 95% object detection on representative bins, more than 90% first-pick success over 500 to 1000 cycles, and calibration drift held below 0.5 mm between service intervals. If your process cannot meet those thresholds in a pilot cell, scaling to multiple lines usually amplifies the problem rather than solving it.
How to Measure Accuracy the Right Way Before You Buy
Procurement mistakes often begin with incomplete acceptance criteria. Many vendors demonstrate robotic bin picking 3D vision accuracy using ideal parts, shallow bins, and favorable lighting. Buyers should instead request a test protocol based on their real production conditions: actual part finishes, actual bin depth, normal contamination, and the intended robot and gripper combination.
A useful benchmark should cover at least five measurement layers: detection rate, pose repeatability, first-pick success, cycle time, and recovery behavior after failure. A system that reaches 98% detection but only 82% first-pick success is not production-ready if manual recovery consumes labor every 20 to 30 parts. Accuracy must be connected to line economics, not reported as an isolated vision metric.
Testing should also be long enough to expose drift. A 20-minute demo is rarely meaningful. A stronger benchmark is 4 to 8 hours of repeated operation or a defined number of bins, such as 50 to 100 cycles, with operator notes on edge cases. This is especially important for plants comparing vision investment against adjacent automation priorities such as AMR orchestration or CNC servo upgrades.
For technical decision-makers, one useful method is to separate “vision confidence” from “grasp confidence.” The vision engine may locate a part with high confidence, but the robot may still lack a collision-free approach path. Reporting both values helps engineering and purchasing teams see whether the bottleneck is perception, motion planning, or end-effector design.
Suggested acceptance checklist for sourcing teams
The following table can be used as a baseline during supplier comparison. It keeps the discussion tied to measurable outcomes and reduces the risk of selecting a system on vague claims such as “high precision” or “smart AI recognition.”
This framework also helps compare costs more fairly. A lower-priced vision package that requires weekly re-tuning, higher operator support, or repeated software exceptions may end up with a worse total cost of ownership over 12 to 24 months than a more stable system with better validation and service support.
Questions buyers should ask during technical review
- What part surfaces were used in the supplier’s benchmark, and how closely do they match the real production finish?
- How often must hand-eye or scene calibration be repeated under normal operation?
- What happens when the bin fill level drops below 20% or when parts nest tightly together?
- Can the supplier provide separate data for detection rate, pick rate, and recovery rate?
- What is the expected support model during the first 30, 60, and 90 days after commissioning?
Implementation, Maintenance, and Cross-System Integration
Once the hardware is selected, deployment discipline determines whether the promised 3D vision accuracy survives beyond factory acceptance testing. A typical implementation can be divided into four stages: feasibility validation, mechanical and electrical integration, calibration and recipe tuning, and production ramp-up. Depending on cell complexity, this may take 2 to 6 weeks, with additional time if the system must connect to MES, PLC logic, AMR material supply, or traceability software.
Integration quality matters because bin picking rarely works in isolation. A poorly timed conveyor handoff, unstable AGV charging station setup affecting replenishment timing, or inconsistent AMR fleet management software dispatch can create irregular bin presentation and force the vision system to work outside its trained assumptions. In this sense, vision accuracy is partly an upstream logistics issue and partly a downstream handling issue.
Maintenance routines should be standardized. Lens cleaning frequency may range from once per shift in oily environments to once per week in sealed electronics assembly areas. Calibration checks should be triggered not only by schedule but also by events such as crashes, bracket replacement, robot base movement, or unexplained pick-rate decline of more than 3% to 5% over a defined monitoring window.
Service support should also be evaluated contractually. Remote diagnostics within 4 to 24 hours, on-site support windows, spare sensor availability, and software rollback procedures all influence production risk. For buyers comparing multiple automation vendors, these service parameters are often more decisive than incremental differences in lab resolution.
A practical rollout path
- Run an application study using real parts, real bins, and target robot paths for at least one representative shift.
- Freeze the camera mount, gripper concept, and bin specification before final software tuning.
- Define acceptance metrics shared by engineering, operations, and procurement teams.
- Train operators on cleaning, alarm handling, and safe recovery steps within the first week after start-up.
- Review performance after 30 days and compare actual pick success against the original business case.
Common implementation mistakes
Frequent errors include validating only full bins, ignoring end-of-bin performance, changing gripper pads after calibration, and treating software confidence as equivalent to real pick success. Another mistake is underestimating mechanical rigidity. Even a small bracket shift from repeated vibration can move the camera enough to create measurable pose error, especially in cells aiming for sub-millimeter grasp accuracy.
FAQ for Engineers, Operators, and Procurement Teams
The questions below reflect common search intent around robotic bin picking 3D vision accuracy and help connect technical specifications with procurement and operational decisions.
How accurate does a robotic bin picking vision system need to be?
The answer depends on part geometry and gripper tolerance. Many industrial cells operate successfully in the range of ±0.5 mm to ±2.0 mm positional accuracy and 1° to 5° angular accuracy. Tight mechanical grippers, small parts, or insertion-dependent handoff steps usually require the lower end of that range. Suction-based picks may tolerate more variation if the contact surface is large and consistent.
Which industries benefit most from improving 3D vision accuracy?
Automotive components, metal machining, electronics, logistics kitting, aerospace subassemblies, and general industrial parts handling all benefit when bins contain randomized or overlapping parts. In these sectors, even a 5% to 8% improvement in first-pick success can significantly reduce manual touchpoints, especially where labor availability is tight or downstream equipment depends on stable feed rates.
What is the biggest misconception during supplier selection?
A common misconception is assuming the highest camera resolution automatically delivers the best robotic bin picking result. In practice, scene stability, calibration routine, software robustness, and gripper tolerance often matter more. Another misconception is accepting a short demo instead of demanding long-run validation under real contamination, lighting, and bin depletion conditions.
How often should the system be recalibrated?
There is no single rule. Stable enclosed cells may only need scheduled verification every 1 to 4 weeks, while high-vibration or frequently serviced lines may need checks every shift or after every mechanical disturbance. The best practice is to define a trigger-based rule set tied to collision events, tool replacement, bracket movement, or a sustained drop in pick success.
Better robotic bin picking 3D vision accuracy comes from aligning sensor choice, calibration discipline, gripper tolerance, test method, and plant integration rather than chasing a single headline specification. For TSV readers, the most reliable path is to compare systems on measurable thresholds: pose error, first-pick success, latency, drift stability, and recovery behavior under real operating conditions.
If your team is assessing bin picking performance as part of a broader automation strategy, the right evaluation framework can reduce supplier qualification cycles, avoid costly retrofits, and protect long-term throughput. Contact us to discuss your application constraints, request a more tailored evaluation checklist, or explore data-driven guidance for robotics, sensors, and advanced manufacturing system selection.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Oct 17, 20265-Axis CNC Positioning Accuracy: How to Interpret ISO 230-2 Test ResultsAssess 5 axis CNC machining positioning accuracy with ISO 230-2. Learn to interpret repeatability, reversal error, and test conditions to compare suppliers and make confident acceptance decisions.Dr. Marcus Vance
 Oct 16, 2026Choosing a Rugged Edge AI Box Supplier: Thermal Tests and Lifecycle SupportChoose a rugged edge AI box supplier with proven thermal performance and reliable lifecycle support. Discover the tests and commitments to verify before you buy.TSV Data Lab
 Oct 15, 2026R&D Cost Reduction Services: How to Evaluate Fees, Savings, and ROIEvaluate R&D cost reduction services with confidence. Compare fees, verify savings, and calculate ROI without compromising performance. Discover how to choose a provider that delivers real value.Chen Wei (Automation Lead Engineer)
 Oct 16, 2026How Can You Fairly Compare MTBF Across Industrial Servo Motors?Make a fair industrial servo motor MTBF comparison with matched operating profiles, failure criteria, and confidence bounds. Discover how to assess reliability beyond advertised numbers.Chen Wei (Automation Lead Engineer)
 Oct 15, 2026How Should You Compare TechStat Vanguard 5-Axis CNC Tolerances?TechStat Vanguard 5-axis CNC tolerance comparison: learn how to verify part accuracy, assess inspection evidence, and choose suppliers that reliably meet your drawing requirements.Dr. Marcus Vance
 Oct 14, 2026Drone Frame Composites: Carbon Fiber vs. Fiberglass for Weight and StiffnessExplore drone structural materials composites: compare carbon fiber and fiberglass for weight, stiffness, cost, and antenna compatibility. Find the right material for your drone frame.Elena Rostova (UAV Systems Researcher)
 Oct 13, 2026Smart Cameras vs. PC-Based Machine Vision: Which Fits High-Speed Inspection?This industrial product comparison for machine vision weighs smart cameras vs. PC-based systems on latency, throughput, and cost. Discover your best fit for high-speed inspection.TSV Data Lab
 Oct 12, 2026How to Verify RoHS Compliance in Industrial Sensing Systems Before DeploymentRoHS compliant sensing systems: learn how to verify materials, supplier declarations, testing, and configuration controls before industrial deployment.TSV Data Lab
 Oct 11, 2026How Procurement-Oriented Content Taxonomy Improves B2B Buying JourneysProcurement-oriented content taxonomy streamlines B2B buying journeys with clearer evidence, supplier comparisons, risk visibility, and faster approvals.TSV Data Lab
 Oct 10, 2026How to Select a Machine Performance Monitoring Platform for OEE and Downtime ReductionMachine performance monitoring platform selection guide: validate machine states, OEE data, downtime reasons, integrations, and scalability to reduce losses with confidence.TSV Data Lab
 Oct 08, 2026How to Machine Inconel 625 Blades Without Heat Cracks or Edge ChippingInconel 625 blade machining guide: prevent heat cracks, edge chipping, chatter, and work hardening with proven tooling, cooling, fixturing, and inspection strategies.Dr. Marcus Vance
 Oct 07, 2026How to Evaluate an HMI Panel Distributor for Industrial Automation ProjectsHMI panel distributor evaluation guide: verify technical compatibility, traceability, supply reliability, lifecycle support, and total cost for automation projects.Victor Lin (Chief Software Architect)
 Oct 06, 2026Navigation Fault Tolerance Standards for AMRs: What Safety Teams Must VerifyNavigation fault tolerance standards: learn what AMR safety teams must verify, from localization loss and sensor faults to stopping distance, safe restart, and site-specific validation.Chen Wei (Automation Lead Engineer)
 Oct 05, 2026Calculating Edge Computing Total Cost of Ownership Across Distributed SitesEdge computing ownership cost explained: calculate deployment, energy, connectivity, security, remote support, and refresh costs across distributed sites.TSV Data Lab
 Oct 04, 2026CAD/CAM Benchmarking in the GCC: What Manufacturers Should Ask a ConsultantCAD CAM benchmark consultant GCC guide: learn the key questions manufacturers should ask to validate post-processors, workflows, machine performance, and production risk.Victor Lin (Chief Software Architect)
 Oct 03, 2026Selecting Automotive Radar Sensor Modules for ADAS Range, Resolution, and IntegrationAutomotive radar sensor module selection guide for ADAS: compare range, resolution, field of view, latency, and integration to build safer, reliable vehicle systems.TSV Data Lab
 Oct 02, 2026How to Qualify Machined Parts Suppliers for Hard Tech ProgramsHard tech supply chain machined parts demand rigorous supplier qualification. Learn how to assess capability, traceability, quality controls, and delivery resilience.Dr. Marcus Vance























