
How Sub-Pixel Recognition Accuracy Affects Edge Detection in Machine Vision Inspection
Publication Date
author
Edge detection sits at the center of machine vision inspection, yet its reliability depends on how precisely a system interprets pixel data. When machine vision sub-pixel recognition accuracy improves, contour transitions become more stable, measurement repeatability increases, and defect boundaries remain clearer under vibration, glare, and normal process variation. In a market crowded with vague imaging claims, this relationship matters because tolerance decisions, supplier comparisons, and line qualification all depend on measurable engineering truth rather than polished marketing language.
Why edge detection becomes a strategic metric
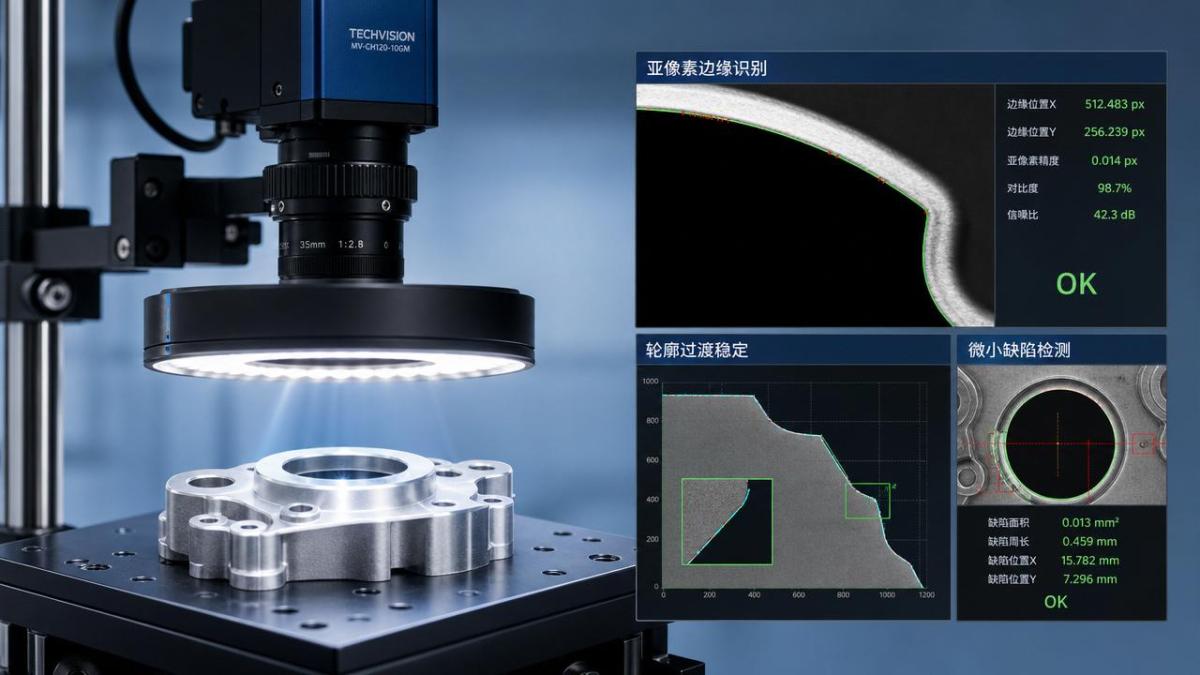
A clean edge is not only a visual boundary. It is the reference used for width, gap, concentricity, flatness, and defect localization.
That is why machine vision sub-pixel recognition accuracy affects much more than image sharpness. It shapes pass or fail decisions across automation, aerospace parts, electronics, packaging, batteries, and medical machining.
At production speed, a one-pixel shift can represent a serious dimensional error. Sub-pixel processing reduces that uncertainty by estimating edge position between discrete pixels.
This is especially relevant in the TSV view of industrial benchmarking. Parameters do not lie, and edge location stability is one of the parameters that exposes real system capability.
What sub-pixel recognition accuracy actually means
A sensor records light in whole pixels, but real edges rarely align perfectly with that grid. An object boundary often falls between neighboring pixel centers.
Sub-pixel algorithms estimate that boundary by analyzing grayscale transition, intensity slope, local contrast, and noise behavior. The result is an edge coordinate finer than one full pixel.
Machine vision sub-pixel recognition accuracy therefore describes how consistently the system can locate that estimated boundary under repeated conditions.
It is not the same as camera resolution. A high-resolution sensor can still deliver unstable edges if optics, lighting, calibration, or processing are weak.
Likewise, a lower-resolution system may produce usable results if optical distortion is controlled and grayscale transitions are strong.
The hidden difference between sharp images and accurate edges
A visually sharp image often impresses during demonstrations. Inspection reliability, however, depends on whether the same edge is found at the same coordinate every cycle.
That is the practical distinction technical reviews should keep in mind. Presentation quality is not measurement integrity.
How accuracy changes inspection results on the line
When machine vision sub-pixel recognition accuracy is low, three failure modes appear quickly. Measurements drift, defect boundaries blur, and false rejects increase during routine environmental change.
The opposite is also true. Better sub-pixel performance tightens repeatability and makes edge-based tools more dependable over long runs.
This is why industrial evaluation should focus on edge repeatability under real conditions, not only lab images captured once under ideal lighting.
Where the issue appears across industries
The topic is broad because edge-based inspection is common across the hard-tech supply chain. Different sectors feel the problem in different ways.
- In precision machining, edge location affects hole diameter checks, chamfer measurement, and burr detection on tight-tolerance parts.
- In electronics, it influences solder boundary analysis, connector pin spacing, and laminated layer alignment.
- In battery and energy systems, it supports electrode coating width, tab position, and seal edge consistency.
- In aerospace composites, it helps verify trim lines, bonded edges, and contour stability on low-contrast materials.
- In robotics and edge AI, it improves machine-side decisions where latency and local processing limit image rework.
This cross-sector relevance explains why TSV places sub-pixel analysis within Sensors and Edge AI benchmarking. It is a practical indicator of whether a vision stack can support high-value manufacturing decisions.
What really controls machine vision sub-pixel recognition accuracy
Accuracy is shaped by the entire imaging chain. Evaluations become misleading when suppliers isolate software claims from physical constraints.
Optics and distortion
Lens quality determines contrast, distortion, and edge sharpness before software even starts. A weak lens can make sub-pixel math look impressive while the raw boundary remains unstable.
Lighting behavior
Backlight, coaxial light, dome light, and directional light create very different edge transitions. Stable lighting usually improves sub-pixel confidence more than algorithm tuning alone.
Sensor noise and exposure
Low signal-to-noise ratio softens grayscale slopes. That makes edge interpolation less trustworthy, especially at higher speeds or lower exposure times.
Calibration and mechanical stability
Even strong algorithms fail if calibration drifts or fixture vibration changes object pose. In practice, machine vision sub-pixel recognition accuracy is partly a mechanical discipline.
Algorithm design
Gradient fitting, interpolation method, filtering strategy, and threshold logic all matter. Some tools perform well on clean edges but collapse on textured or reflective surfaces.
How to evaluate claims without relying on vendor language
A useful review starts by asking how machine vision sub-pixel recognition accuracy was measured, not whether the brochure mentions it.
The most informative comparisons are usually built around controlled repetition, known references, and environmental variation.
- Test repeated edge localization on the same calibrated feature over many cycles.
- Compare static and dynamic results to reveal motion sensitivity.
- Record performance under brightness variation, mild defocus, and reflective changes.
- Check whether reported values refer to best case, average case, or worst case.
- Verify whether edge accuracy remains stable across the full field of view.
- Link image metrics to process metrics such as false reject rate or gauge repeatability.
This approach aligns with TSV’s broader position on hard-tech evaluation. Trust should be built through traceable parameters, not adjectives.
Practical interpretation for system selection
In actual sourcing or line-upgrade work, the best question is rarely, “Which camera has the highest stated precision?”
A better question is whether the full vision stack can maintain edge fidelity within the process tolerance window.
That means linking machine vision sub-pixel recognition accuracy to part geometry, speed, material reflectivity, lighting access, and acceptance criteria.
For some lines, the priority is micro-defect visibility. For others, repeatable metrology matters more than visual contrast. The correct weighting changes with failure cost.
It also helps to separate three layers during evaluation: image formation, edge computation, and decision logic. When one layer underperforms, improvements in another may not solve the root cause.
A clearer next step for technical benchmarking
Edge detection performance becomes meaningful when it is tested against production reality, not showroom conditions. That is where machine vision sub-pixel recognition accuracy stops being a buzz phrase and becomes a selection criterion.
The next step is to define a reference part, map the critical edges, and compare repeatability under the same lighting, speed, and tolerance rules expected on the line.
From there, benchmark systems by data transparency: edge localization spread, calibration stability, defect boundary consistency, and failure behavior under variation.
That method reduces trial-and-error cost, shortens qualification cycles, and fits the broader TSV principle that engineering decisions should be anchored in verifiable parameters.
When the edge is trusted, the inspection result becomes easier to trust as well. That is the standard worth carrying into every next comparison.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Oct 22, 2026KUKA Showcases Physical AI and iiQKA.AI Vision at NVIDIA GTC BerlinExplore KUKA’s Physical AI showcase at NVIDIA GTC Berlin and discover how iiQKA.AI Vision aims to simplify robotic vision integration and improve 2D and 3D scene recognition.TSV Data Lab
 Oct 22, 2026Robotic Machining of Advanced Composites: What Tolerances Are Achievable?Explore advanced materials machining robotics: discover what drives achievable composite tolerances and how to validate accuracy before investing in your next machining system.Dr. Marcus Vance
 Oct 21, 2026China’s Industrial Robot Exports Near RMB 10 Billion in First Nine Months of 2026China’s industrial robot exports neared RMB 10 billion in January–September 2026, with value rising faster than volume. Explore the data and what it could mean for suppliers.Chen Wei (Automation Lead Engineer)
 Oct 21, 2026Low-Latency Industrial Data Processing: Pricing and Key Cost DriversExplore industrial data latency price drivers, from edge hardware to integration and support. Learn how to compare quotes, verify performance, and avoid unnecessary costs.TSV Data Lab
 Oct 20, 2026KUKA Launches iiQKA.AI Vision to Simplify Industrial Image ProcessingKUKA iiQKA.AI Vision simplifies industrial image processing with controller-based 2D and 3D vision. Explore drag-and-drop setup for vision-guided automation.TSV Data Lab
 Oct 20, 2026Smart Industrial Edge Devices: Key Criteria for Legacy PLC IntegrationChoose smart industrial edge devices for legacy PLC integration. Discover key criteria for compatibility, data quality, security, and reliable collection without disrupting control.TSV Data Lab
 Oct 19, 2026Choosing a Radar Sensor by Application: Range, Resolution, and Field of ViewSimplify radar sensor application based product selection. Compare range, resolution, and field of view to avoid blind spots and choose with confidence. Explore the guide.TSV Data Lab
 Oct 18, 2026Comparing Material Options for Procurement: Specs, Costs, and Supply RisksExplore procurement oriented technical content on material options, specs, costs, and supply risks. Compare alternatives to cut hidden expenses and make confident sourcing decisions.Dr. Marcus Vance
 Oct 17, 20265-Axis CNC Positioning Accuracy: How to Interpret ISO 230-2 Test ResultsAssess 5 axis CNC machining positioning accuracy with ISO 230-2. Learn to interpret repeatability, reversal error, and test conditions to compare suppliers and make confident acceptance decisions.Dr. Marcus Vance
 Oct 16, 2026Choosing a Rugged Edge AI Box Supplier: Thermal Tests and Lifecycle SupportChoose a rugged edge AI box supplier with proven thermal performance and reliable lifecycle support. Discover the tests and commitments to verify before you buy.TSV Data Lab
 Oct 15, 2026R&D Cost Reduction Services: How to Evaluate Fees, Savings, and ROIEvaluate R&D cost reduction services with confidence. Compare fees, verify savings, and calculate ROI without compromising performance. Discover how to choose a provider that delivers real value.Chen Wei (Automation Lead Engineer)
 Oct 21, 2026How Should You Balance Cobot Payload Against Reach?Explore cobot payload versus reach to choose the right robot. Learn how tooling, load limits, workspace, and cycle time affect performance—and avoid costly selection mistakes.Chen Wei (Automation Lead Engineer)
 Oct 20, 2026How Do You Measure Industrial IoT Gateway Latency Under Load?Measure industrial IoT gateway latency under load with reliable timestamps, realistic traffic, and tail-latency analysis. Discover how to expose bottlenecks and choose the right gateway.TSV Data Lab
 Oct 19, 2026How Do You Verify That Precision Machined Parts Meet Tolerances?Master precision machining tolerance verification with the right tools, datum setups, and acceptance rules. Learn how to validate parts confidently and reduce costly inspection errors.Dr. Marcus Vance
 Oct 18, 2026What Should an AS9100 Machining Supplier Checklist Include?Build an AS9100 machining supplier checklist that verifies capability, traceability, inspection, and outsourced processes. Discover what to check before approving your next aerospace supplier.Dr. Marcus Vance
 Oct 17, 2026How Should You Interpret Industrial Robot Repeatability Specs?Decode industrial robot repeatability specifications, understand ISO 9283 test conditions, and avoid costly selection mistakes. Learn how to verify performance for your process.Chen Wei (Automation Lead Engineer)
 Oct 16, 2026How Can You Fairly Compare MTBF Across Industrial Servo Motors?Make a fair industrial servo motor MTBF comparison with matched operating profiles, failure criteria, and confidence bounds. Discover how to assess reliability beyond advertised numbers.Chen Wei (Automation Lead Engineer)























