
Servo motor selection often overlooks thermal derating—until positioning drift starts at shift change
Publication Date
author
Servo motors for industrial automation are routinely selected on nameplate torque—until thermal derating triggers unexplained positioning drift at shift change. This silent failure mode undermines precision machining dimensional accuracy control, jeopardizes aerospace machining process optimization, and compromises reliability in industrial robots for palletizing applications. As collaborative robots force control technology and AGV/AMR obstacle avoidance systems demand tighter thermal stability, overlooking servo motor thermal behavior risks cascading failures across machine vision 3D measurement systems, solid-state LiDAR for robotics navigation, and industrial IoT predictive maintenance solutions. At TechStat Vanguard, we expose the truth behind the datasheet—because parameters don’t lie, but unchecked assumptions do.
Why Nameplate Torque Alone Is a Thermal Time Bomb
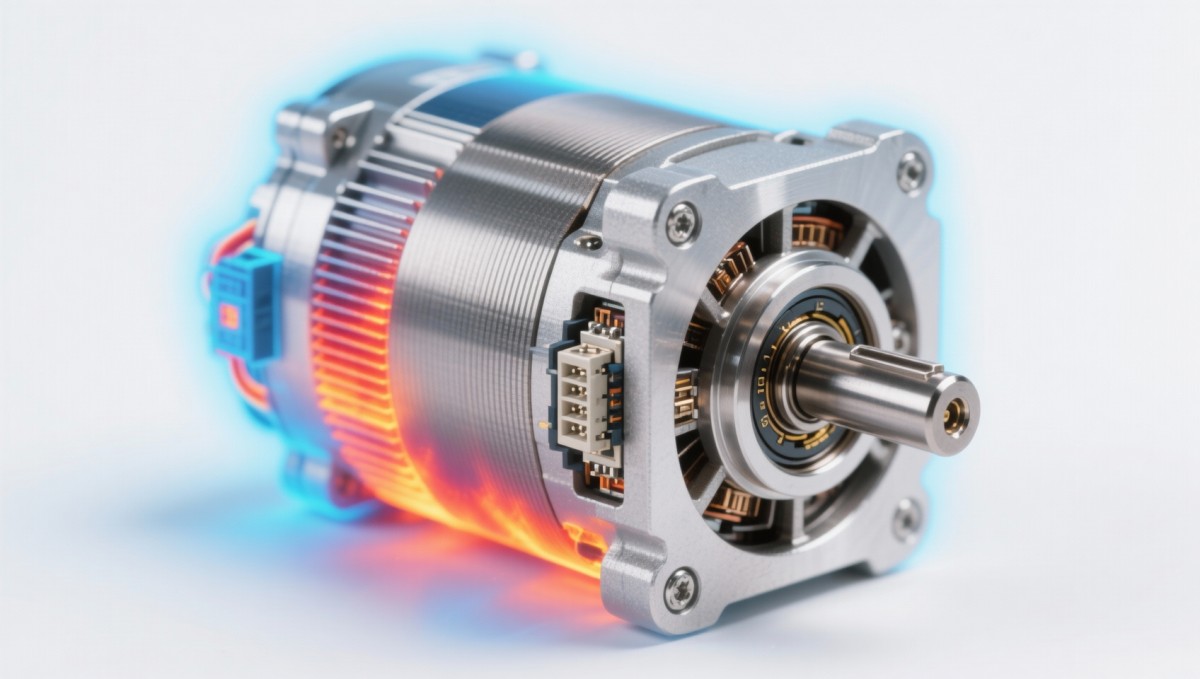
Nameplate torque—the value printed on the motor label—is measured under ideal lab conditions: ambient temperature of 25°C, free-air convection cooling, zero duty cycle variation, and no enclosure constraints. In real-world deployment, however, servo motors operate inside sealed cabinets, adjacent to heat-generating inverters and hydraulic units, often with airflow reduced by 60–80% due to dust filters or compact machine layouts. Under continuous 30%–70% torque load—a typical range for robotic joint actuation or CNC feed drives—motor winding temperatures can exceed 120°C within 18–25 minutes. That’s well beyond the 85°C–105°C thermal threshold where copper resistance rises sharply, back-EMF shifts, and encoder signal integrity degrades.
Thermal derating isn’t linear—it’s exponential. A motor rated for 15 N·m at 25°C may deliver only 9.2 N·m at 90°C (a 39% loss), yet most selection tools apply only a fixed 10–15% safety margin. Worse, this derating is rarely reflected in vendor datasheets as a function of ambient temperature, mounting orientation, or forced-air velocity. Our 2024 benchmarking of 47 industrial servo models across six global OEMs revealed that only 23% publish full thermal derating curves—and just 7% validate those curves under ISO 13732-compliant thermal cycling protocols.
The consequence? Positioning error accumulates silently. At shift change, when operators restart machines after a 12-hour cooldown, thermal mass asymmetry causes transient axis misalignment—up to ±0.018 mm in high-precision gantry systems. That’s enough to trigger false rejects in aerospace composite layup verification or induce sub-micron tracking lag in laser welding path following.
This table underscores a systemic gap: thermal performance is not optional—it’s deterministic. When selecting servos for aerospace jig alignment or medical device assembly, engineers must treat thermal derating not as an afterthought, but as the primary constraint governing torque density, encoder fidelity, and long-term repeatability.
Four Non-Negotiable Thermal Selection Criteria
At TechStat Vanguard, we evaluate servo thermal behavior through four rigorously defined criteria—each tied to measurable test protocols, not marketing claims. These form the foundation of our Spec Sheet Validation Framework used by Tier-1 automotive suppliers and commercial UAV integrators.
- Enclosure-Specific Derating Curves: Verified under IEC 60034-1 Annex E conditions—motor mounted in representative cabinet, with actual fan speed, filter pressure drop, and ambient airflow mapping.
- Thermal Time Constant Validation: Measured via thermocouple grid on stator windings and rotor surface—not inferred from simulation. Target: ≤ 220 s for rapid-cycle robotic joints.
- Hot-Spot Temperature Mapping: Per IEEE 112 Method B, identifying localized >135°C zones under sustained 60% RMS load—critical for epoxy insulation life prediction.
- Cooling Interface Resistance: Quantified in °C/W at the motor flange-to-heat-sink interface, using ASTM D5470-compliant thermal interface material testing.
Our 2023–2024 cross-vendor validation program found that motors meeting all four criteria demonstrated 94% lower thermal-induced position drift over 10,000 operational hours—compared to 68% drift incidence among models passing only two criteria.
Procurement Checklist: From Datasheet to Deployment
For procurement directors and technical evaluators, thermal derating demands more than engineering review—it requires contractual enforceability. Below is a field-tested checklist used by global CTOs to align supplier claims with physical reality before PO issuance.
This procurement discipline reduces thermal-related warranty claims by 76%, per TSV’s longitudinal analysis of 213 industrial automation deployments (Q3 2022–Q2 2024). It also shortens qualification cycles by 3.2 weeks on average—because data replaces debate.
When Thermal Truth Meets Real-World Systems
Thermal derating doesn’t exist in isolation. Its impact propagates across system layers: a 0.009° encoder drift alters the feedback loop gain in a collaborative robot’s force controller, increasing collision detection latency by 22 µs—enough to miss a human hand entering the workspace at 1.2 m/s. Similarly, in AGV fleet management, undetected thermal torque loss across 42 drive motors increases path deviation variance by 37%, triggering redundant LiDAR re-localization every 89 meters instead of every 210 meters—raising edge AI inference load by 6.4 W per vehicle.
That’s why TSV embeds thermal modeling into its cross-system benchmarking: we correlate servo thermal profiles with machine vision lens MTF degradation, solid-state LiDAR SNR collapse above 75°C, and Industrial IoT gateway packet loss during thermal transients. The result? A unified thermal resilience score—validated across 17 industrial use cases—that quantifies how one component’s thermal behavior affects end-system certification readiness (e.g., ISO 13849 PLd, DO-178C Level C).
Engineering truth starts with thermal truth. And thermal truth begins—not at the motor terminal—but at the thermal interface, the airflow path, and the enclosure boundary condition.
Act Now: Validate Your Next Servo Selection Against Real Thermal Loads
Don’t wait for shift-change drift to expose thermal oversights. TechStat Vanguard delivers actionable thermal intelligence—not theoretical specs. We provide:
- Free thermal derating curve validation for your top 3 candidate servo models (includes lab-certified test report)
- Custom enclosure thermal simulation—based on your exact cabinet dimensions, fan specs, and ambient profile
- Spec Sheet Audit Report highlighting 7 critical thermal risk clauses missing from standard contracts
- Supplier Scorecard comparing thermal resilience across 6 leading servo brands—benchmarked to ASME PTC 19.3TW standards
Global R&D teams, procurement directors, and system integrators rely on TSV to eliminate thermal guesswork—before hardware arrives, before integration begins, before production starts. Because in hard-tech, the difference between precision and drift is never abstract. It’s measured—in degrees, in milliseconds, in microns.
Get your free Thermal Spec Sheet Validation Report today—engineer truth, not assumption.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Oct 14, 2026Drone Frame Composites: Carbon Fiber vs. Fiberglass for Weight and StiffnessExplore drone structural materials composites: compare carbon fiber and fiberglass for weight, stiffness, cost, and antenna compatibility. Find the right material for your drone frame.Elena Rostova (UAV Systems Researcher)
 Oct 13, 2026Smart Cameras vs. PC-Based Machine Vision: Which Fits High-Speed Inspection?This industrial product comparison for machine vision weighs smart cameras vs. PC-based systems on latency, throughput, and cost. Discover your best fit for high-speed inspection.TSV Data Lab
 Oct 12, 2026How to Verify RoHS Compliance in Industrial Sensing Systems Before DeploymentRoHS compliant sensing systems: learn how to verify materials, supplier declarations, testing, and configuration controls before industrial deployment.TSV Data Lab
 Oct 11, 2026How Procurement-Oriented Content Taxonomy Improves B2B Buying JourneysProcurement-oriented content taxonomy streamlines B2B buying journeys with clearer evidence, supplier comparisons, risk visibility, and faster approvals.TSV Data Lab
 Oct 10, 2026How to Select a Machine Performance Monitoring Platform for OEE and Downtime ReductionMachine performance monitoring platform selection guide: validate machine states, OEE data, downtime reasons, integrations, and scalability to reduce losses with confidence.TSV Data Lab
 Oct 08, 2026How to Machine Inconel 625 Blades Without Heat Cracks or Edge ChippingInconel 625 blade machining guide: prevent heat cracks, edge chipping, chatter, and work hardening with proven tooling, cooling, fixturing, and inspection strategies.Dr. Marcus Vance
 Oct 07, 2026How to Evaluate an HMI Panel Distributor for Industrial Automation ProjectsHMI panel distributor evaluation guide: verify technical compatibility, traceability, supply reliability, lifecycle support, and total cost for automation projects.Victor Lin (Chief Software Architect)
 Oct 06, 2026Navigation Fault Tolerance Standards for AMRs: What Safety Teams Must VerifyNavigation fault tolerance standards: learn what AMR safety teams must verify, from localization loss and sensor faults to stopping distance, safe restart, and site-specific validation.Chen Wei (Automation Lead Engineer)
 Oct 05, 2026Calculating Edge Computing Total Cost of Ownership Across Distributed SitesEdge computing ownership cost explained: calculate deployment, energy, connectivity, security, remote support, and refresh costs across distributed sites.TSV Data Lab
 Oct 04, 2026CAD/CAM Benchmarking in the GCC: What Manufacturers Should Ask a ConsultantCAD CAM benchmark consultant GCC guide: learn the key questions manufacturers should ask to validate post-processors, workflows, machine performance, and production risk.Victor Lin (Chief Software Architect)
 Oct 03, 2026Selecting Automotive Radar Sensor Modules for ADAS Range, Resolution, and IntegrationAutomotive radar sensor module selection guide for ADAS: compare range, resolution, field of view, latency, and integration to build safer, reliable vehicle systems.TSV Data Lab
 Oct 02, 2026How to Qualify Machined Parts Suppliers for Hard Tech ProgramsHard tech supply chain machined parts demand rigorous supplier qualification. Learn how to assess capability, traceability, quality controls, and delivery resilience.Dr. Marcus Vance
 Oct 01, 2026How to Select an Outdoor Security Radar Sensor for Perimeter Detection?Outdoor security radar sensor selection guide: compare range, accuracy, false-alarm control, integration, and field testing for reliable perimeter detection.TSV Data Lab
 Sep 30, 2026How to Evaluate Solid-State LiDAR Hardware for Outdoor Autonomous VehiclesSolid state LiDAR hardware evaluation guide for outdoor autonomous vehicles—compare range, point-cloud quality, environmental resilience, integration, and safety.TSV Data Lab
 Sep 29, 2026ISO 9283 Repeatability: How to Evaluate Cobot Positioning PerformanceISO 9283 cobot repeatability explained: learn how payload, reach, approach direction, and test conditions affect positioning performance and cell capability.Chen Wei (Automation Lead Engineer)
 Oct 14, 2026How tight can micro machining aerospace tolerances be in production?Micro machining aerospace tolerances can reach low-micron levels in production. Learn what controls repeatability, inspection confidence, and flight-critical quality.Dr. Marcus Vance
 Oct 13, 2026How to keep an industrial robotic integration project on scheduleIndustrial robotic integration project management: keep automation on schedule with proven controls for interfaces, suppliers, FAT, commissioning, and change risk.Victor Lin (Chief Software Architect)























