
How to Choose a Robotic Gripper Manufacturer for Cobot Applications
Publication Date
author
Selecting a robotic gripper manufacturer for cobot applications is not a branding exercise; it is a technical risk assessment.
Payload curves, gripping force stability, repeatability, safety compliance, material compatibility, and lifecycle reliability decide whether a gripper survives real production.
As cobots move from pilot cells into mixed-model manufacturing, every robotic gripper manufacturer must prove performance through data, not adjectives.
Cobot Gripping Is Shifting From Demonstration Value to Production Evidence
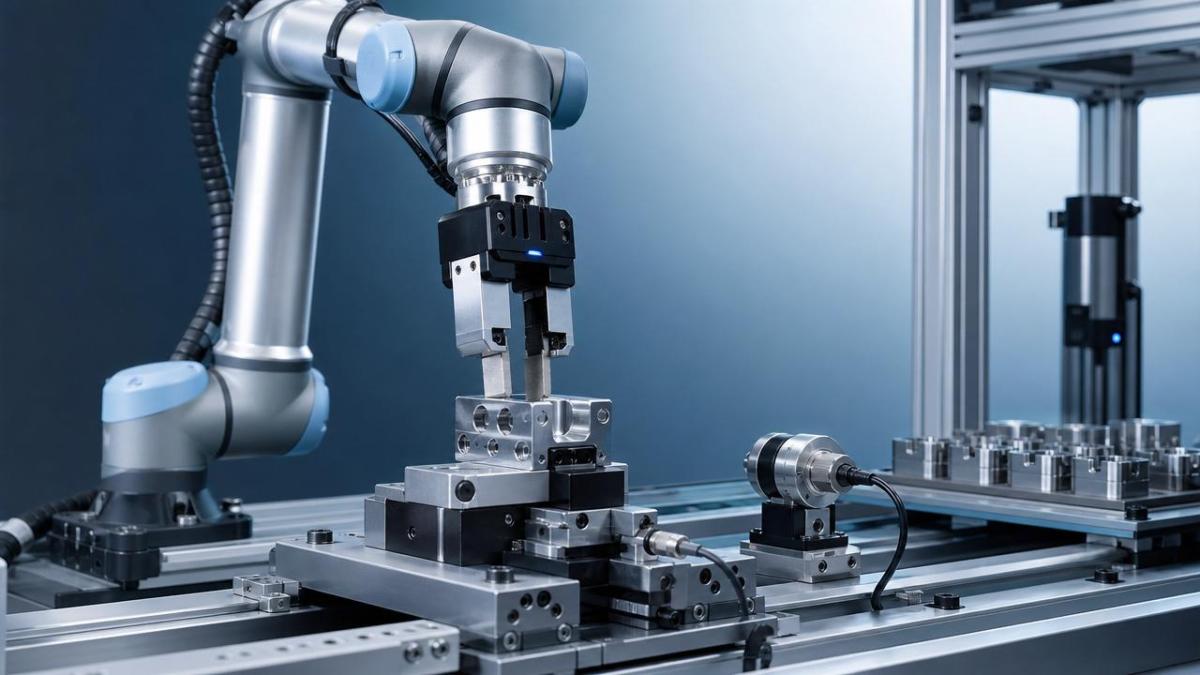
The cobot market is entering a more disciplined phase. Early adoption often accepted flexible demos and simple pick-and-place success.
Current deployments demand uptime, traceable validation, safe human interaction, and quick redeployment across products, fixtures, and shifts.
This change raises the standard for every robotic gripper manufacturer serving collaborative automation, electronics assembly, packaging, machining, and laboratory handling.
A gripper now operates as a measurable end-effector system, not an accessory. Its performance influences cycle time, scrap rate, and line confidence.
A credible robotic gripper manufacturer should therefore publish engineering limits, test conditions, safety data, and integration constraints in verifiable form.
Why Supplier Selection Criteria Are Becoming More Technical
Several forces are reshaping how a robotic gripper manufacturer is evaluated in cobot applications.
These drivers make catalog specifications insufficient. A robotic gripper manufacturer must demonstrate how ratings were measured, not only what numbers appear.
For TechStat Vanguard, the decisive question is simple: which parameters remain stable after heat, dust, vibration, and repetitive cycles?
Core Metrics That Separate Engineering Evidence From Marketing Claims
A qualified robotic gripper manufacturer should provide a testable baseline across mechanical, electrical, software, and safety dimensions.
Grip force consistency
Peak gripping force is less useful than force stability over time. Drift can damage parts or cause undetected drops.
Ask whether force data covers multiple strokes, temperature ranges, duty cycles, and jaw configurations.
Repeatability and jaw position accuracy
Repeatability affects insertion, machine tending, and precision placement. A robotic gripper manufacturer should distinguish mechanical repeatability from system-level repeatability.
The most useful data includes testing speed, payload, finger length, and mounting orientation.
Payload derating under real geometry
Payload ratings may assume centered loads and short fingers. Real applications often create torque, inertia, and off-axis stress.
A responsible robotic gripper manufacturer publishes moment limits, finger length curves, and acceleration-related derating guidance.
Lifecycle and MTBF evidence
Lifecycle claims must define cycles, environment, payload, maintenance intervals, and failure criteria.
Without these conditions, “millions of cycles” is a marketing phrase, not an engineering benchmark.
Safety and Compliance Are Becoming Buying Constraints
Cobot applications operate near people, so the gripper affects risk assessment as much as the robot arm.
A robotic gripper manufacturer should support ISO 10218, ISO/TS 15066 considerations, CE documentation, and electrical safety requirements where applicable.
Soft edges, force limiting, safe stop behavior, and predictable release states all matter in collaborative workspaces.
- Check maximum pinch force under normal and fault conditions.
- Verify behavior during power loss, communication loss, and emergency stop.
- Confirm whether fingers, pads, and brackets create sharp collision points.
- Request application notes for safe gripping near human operators.
The best robotic gripper manufacturer will not promise universal safety. It will provide evidence needed for application-specific risk reduction.
Integration Depth Now Determines Deployment Speed
Cobot projects often fail through integration friction, not mechanical incapability.
A robotic gripper manufacturer should support common cobot brands, fieldbus protocols, plug-ins, CAD models, and documented wiring schemes.
Strong integration support reduces commissioning time, programming uncertainty, and hidden engineering labor.
Signals of mature integration support
- Native software blocks for major cobot ecosystems.
- Clear digital I/O, Ethernet, Modbus, IO-Link, or EtherCAT documentation.
- Accessible 3D models with mass and center-of-gravity data.
- Application examples for packaging, assembly, loading, inspection, and testing.
When a robotic gripper manufacturer treats software as secondary, the final system may require unnecessary custom work.
Application Fit Matters More Than Universal Claims
No single gripper architecture solves every cobot requirement. Selection should follow the physics of the task.
A robotic gripper manufacturer with broad application evidence is usually safer than one presenting only polished demonstration videos.
The strongest proof is repeatable performance under the exact part geometry, surface condition, and process rhythm.
Lifecycle Economics Are Replacing Unit Price Comparisons
Low initial price can become expensive if spare parts, replacement fingers, software support, or maintenance windows are unclear.
A robotic gripper manufacturer should provide lifecycle cost signals, including wear components, repair options, lead times, and firmware update policy.
Downtime cost often exceeds component cost. This is especially true in lines where cobots support multiple production steps.
- Compare expected service intervals under real duty cycles.
- Check availability of jaws, pads, seals, cables, and controller parts.
- Review warranty exclusions related to contamination or overload.
- Evaluate whether diagnostics reduce troubleshooting time.
A transparent robotic gripper manufacturer will make maintenance assumptions visible before purchase, not after a failure event.
How to Benchmark a Robotic Gripper Manufacturer Before Shortlisting
A structured benchmark avoids subjective selection and exposes specification gaps early.
- Define part geometry, mass, surface, orientation, and cycle target.
- Calculate payload, torque, finger length, and acceleration requirements.
- Request force curves, repeatability data, lifecycle test conditions, and safety documents.
- Validate integration with the selected cobot controller and communication architecture.
- Run sample testing using production parts, not idealized samples.
- Score suppliers by evidence quality, not presentation quality.
This process turns the robotic gripper manufacturer decision into a measurable qualification exercise.
It also reduces redesign risk when moving from proof-of-concept to continuous operation.
Warning Signs That Require Deeper Technical Review
Some warning signs appear before any hardware is installed.
- Specifications lack test conditions or environmental assumptions.
- Payload ratings ignore finger length and moment limits.
- Safety language is broad but not linked to standards.
- Software support depends on undocumented custom scripts.
- Lifecycle claims are presented without failure criteria.
- Sample testing uses simplified parts unrelated to production conditions.
Any robotic gripper manufacturer can claim reliability. Only a technically mature supplier can explain where reliability ends.
A Practical Decision Matrix for Cobot End-Effectors
The final choice should balance measurable performance, integration maturity, compliance evidence, and long-term support.
This matrix helps compare each robotic gripper manufacturer with the same technical lens.
It also prevents overvaluing a single impressive metric while ignoring deployment constraints.
What the Next Phase of Cobot Gripping Will Reward
The next wave will favor grippers with sensing, diagnostics, modular tooling, and transparent data history.
A future-ready robotic gripper manufacturer will connect mechanical capability with edge intelligence and traceable process feedback.
Expect more demand for embedded force sensing, predictive maintenance indicators, and configurable software profiles.
The market will also reward suppliers that publish realistic operating envelopes instead of ideal laboratory maximums.
In data-driven automation, truth is not the largest number. It is the number that remains valid under production stress.
Next Step: Build the Selection Around Verifiable Parameters
Choosing a robotic gripper manufacturer should begin with the application physics, then move toward supplier evidence.
Document part conditions, required cycle rates, safety assumptions, integration interfaces, and maintenance limits before requesting quotations.
Then compare each robotic gripper manufacturer by measured performance, not by claims of being advanced, flexible, or premium.
TechStat Vanguard’s principle applies directly here: parameters do not lie; tolerances dictate success.
For cobot gripping, the strongest decision is the one supported by test conditions, repeatable data, and operational proof.
Search News
Hot Articles
- Carbon Fiber StructuresHow to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsJul 11, 2026
- Machine VisionXiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsMar 30, 2026
- Cobots & ArmsShanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsMar 30, 2026
Popular Tags
Recommended News
 Jul 11, 2026How to Specify Aerospace Carbon Fiber Assemblies for Lightweight, Load-Bearing PartsAerospace carbon fiber assemblies: learn how to specify laminate design, load data, joining methods, and inspection controls for lighter, reliable load-bearing aerospace parts.Elena Rostova (UAV Systems Researcher)
 Mar 30, 2026Xiaomi, Alibaba DAMO Academy Drive Open-Source Robotics Model Ecosystem, Lowering Algorithm Development Barriers for Overseas SMEs Adopting Chinese Robotics SolutionsXiaomi & Alibaba DAMO Academy's open-source robotics models lower algorithm barriers for global SMEs. Boost efficiency in manufacturing, logistics & smart retail with ROS 2 compatible solutions.TSV Data Lab
 Mar 30, 2026Shanxi 'AI+' Conference Showcases Embodied Intelligence with Multinational Buyer Engagement: Key Industry ImplicationsShanxi 'AI+' Conference highlights embodied intelligence with Tesla, Ubtech & Jiantao showcasing multimodal robotics. 40+ global buyers validated tech on-site, creating new B2B channels for industrial automation & AI solutions.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Zhongguancun Unveils 6G Integrated Sensing-Computing-Intelligence Platform to Empower Embodied Robots for Global Industrial ApplicationsZhongguancun's new 6G platform revolutionizes industrial robotics with <10ms latency, empowering global automotive, logistics & port automation. Discover how this tech boosts China's smart manufacturing exports.TSV Data Lab
 Mar 30, 2026Mech-Mind Tianjin Embodied Intelligence R&D and Production Base Goes Live, Cutting Delivery Time by 20%–30% for Global Customized AMR+Vision SolutionsMech-Mind's Tianjin AMR+Vision production base cuts delivery time by 20%-30% for欧美 & Latin American markets. Discover how this PLd-certified facility accelerates customized robotics solutions for smart manufacturing and logistics.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026Boao Forum Reveals 'Co-evolution of Big and Small Brains' Trend in Humanoid Robots, China's Embodied Intelligence Accelerates Adaptation to Overseas Manufacturing Service ScenariosDiscover how China's humanoid robots, featuring 'Co-evolution of Big and Small Brains,' are revolutionizing global manufacturing. Learn about Embodied Tian Gong 3.0's ISO compliance and overseas deployment at Boao Forum 2026.Chen Wei (Automation Lead Engineer)
 Mar 30, 2026China Railway Industrial Secures Patent for Embodied Robotics in Material Handling, Boosting High-Precision Delivery Capabilities for Overseas Infrastructure and Manufacturing ProjectsChina Railway Industrial's new patent for embodied robotics in material handling boosts high-precision delivery for global infrastructure & manufacturing. Discover how this innovation enhances logistics accuracy in automotive, rail transit & EPC projects.Chen Wei (Automation Lead Engineer)
 Oct 17, 20265-Axis CNC Positioning Accuracy: How to Interpret ISO 230-2 Test ResultsAssess 5 axis CNC machining positioning accuracy with ISO 230-2. Learn to interpret repeatability, reversal error, and test conditions to compare suppliers and make confident acceptance decisions.Dr. Marcus Vance
 Oct 16, 2026Choosing a Rugged Edge AI Box Supplier: Thermal Tests and Lifecycle SupportChoose a rugged edge AI box supplier with proven thermal performance and reliable lifecycle support. Discover the tests and commitments to verify before you buy.TSV Data Lab
 Oct 15, 2026R&D Cost Reduction Services: How to Evaluate Fees, Savings, and ROIEvaluate R&D cost reduction services with confidence. Compare fees, verify savings, and calculate ROI without compromising performance. Discover how to choose a provider that delivers real value.Chen Wei (Automation Lead Engineer)
 Oct 16, 2026How Can You Fairly Compare MTBF Across Industrial Servo Motors?Make a fair industrial servo motor MTBF comparison with matched operating profiles, failure criteria, and confidence bounds. Discover how to assess reliability beyond advertised numbers.Chen Wei (Automation Lead Engineer)
 Oct 15, 2026How Should You Compare TechStat Vanguard 5-Axis CNC Tolerances?TechStat Vanguard 5-axis CNC tolerance comparison: learn how to verify part accuracy, assess inspection evidence, and choose suppliers that reliably meet your drawing requirements.Dr. Marcus Vance
 Oct 14, 2026Drone Frame Composites: Carbon Fiber vs. Fiberglass for Weight and StiffnessExplore drone structural materials composites: compare carbon fiber and fiberglass for weight, stiffness, cost, and antenna compatibility. Find the right material for your drone frame.Elena Rostova (UAV Systems Researcher)
 Oct 13, 2026Smart Cameras vs. PC-Based Machine Vision: Which Fits High-Speed Inspection?This industrial product comparison for machine vision weighs smart cameras vs. PC-based systems on latency, throughput, and cost. Discover your best fit for high-speed inspection.TSV Data Lab
 Oct 12, 2026How to Verify RoHS Compliance in Industrial Sensing Systems Before DeploymentRoHS compliant sensing systems: learn how to verify materials, supplier declarations, testing, and configuration controls before industrial deployment.TSV Data Lab
 Oct 11, 2026How Procurement-Oriented Content Taxonomy Improves B2B Buying JourneysProcurement-oriented content taxonomy streamlines B2B buying journeys with clearer evidence, supplier comparisons, risk visibility, and faster approvals.TSV Data Lab
 Oct 10, 2026How to Select a Machine Performance Monitoring Platform for OEE and Downtime ReductionMachine performance monitoring platform selection guide: validate machine states, OEE data, downtime reasons, integrations, and scalability to reduce losses with confidence.TSV Data Lab
 Oct 08, 2026How to Machine Inconel 625 Blades Without Heat Cracks or Edge ChippingInconel 625 blade machining guide: prevent heat cracks, edge chipping, chatter, and work hardening with proven tooling, cooling, fixturing, and inspection strategies.Dr. Marcus Vance
 Oct 07, 2026How to Evaluate an HMI Panel Distributor for Industrial Automation ProjectsHMI panel distributor evaluation guide: verify technical compatibility, traceability, supply reliability, lifecycle support, and total cost for automation projects.Victor Lin (Chief Software Architect)
 Oct 06, 2026Navigation Fault Tolerance Standards for AMRs: What Safety Teams Must VerifyNavigation fault tolerance standards: learn what AMR safety teams must verify, from localization loss and sensor faults to stopping distance, safe restart, and site-specific validation.Chen Wei (Automation Lead Engineer)
 Oct 05, 2026Calculating Edge Computing Total Cost of Ownership Across Distributed SitesEdge computing ownership cost explained: calculate deployment, energy, connectivity, security, remote support, and refresh costs across distributed sites.TSV Data Lab
 Oct 04, 2026CAD/CAM Benchmarking in the GCC: What Manufacturers Should Ask a ConsultantCAD CAM benchmark consultant GCC guide: learn the key questions manufacturers should ask to validate post-processors, workflows, machine performance, and production risk.Victor Lin (Chief Software Architect)
 Oct 03, 2026Selecting Automotive Radar Sensor Modules for ADAS Range, Resolution, and IntegrationAutomotive radar sensor module selection guide for ADAS: compare range, resolution, field of view, latency, and integration to build safer, reliable vehicle systems.TSV Data Lab
 Oct 02, 2026How to Qualify Machined Parts Suppliers for Hard Tech ProgramsHard tech supply chain machined parts demand rigorous supplier qualification. Learn how to assess capability, traceability, quality controls, and delivery resilience.Dr. Marcus Vance























